Description
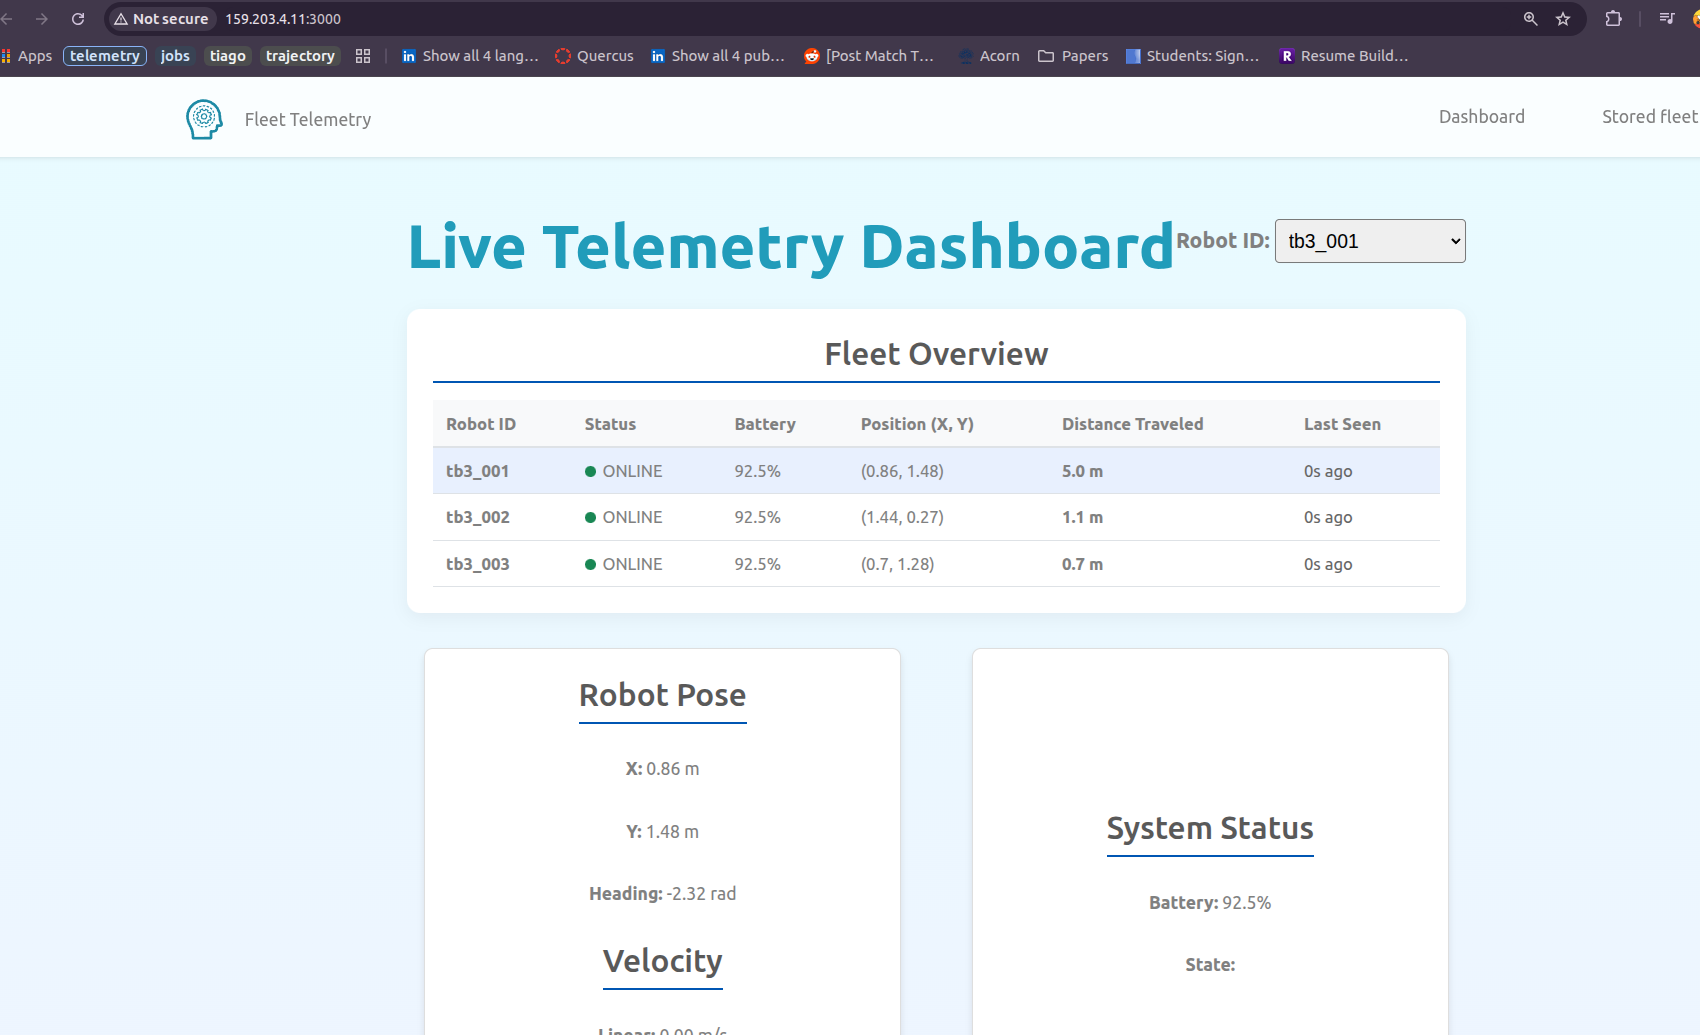
Robot Fleet Telemetry & Control connects simulated TurtleBot3 fleets in ROS 2/Gazebo to a real-time React dashboard. A Python ROS 2 bridge streams robot telemetry over WebSockets to FastAPI, while the dashboard sends remote control and Nav2 navigation commands. PostgreSQL stores fleet and session data.
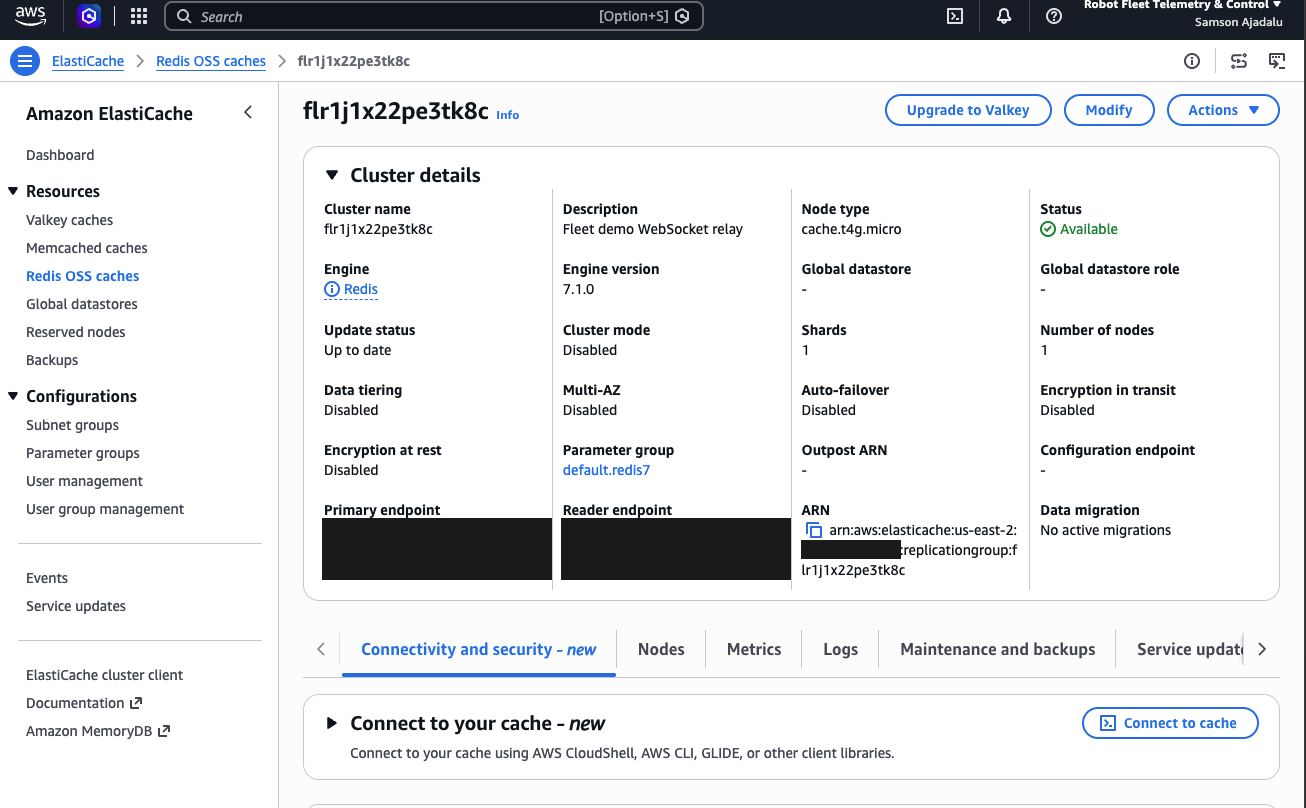
Redis Pub/Sub routes telemetry and commands between independent FastAPI instances. The platform is deployed on AWS with two ECS Fargate API tasks, ElastiCache Redis, RDS PostgreSQL, and a dashboard served through S3/CloudFront. GitHub Actions CI validates the frontend, infrastructure code, Redis relay, and cross-replica WebSocket messaging.
Screenshots
Links & References
- GitHub: robot-fleet-telemetry-control
Expanded from the original University of Toronto Metal-to-Cloud Telemetry team project.